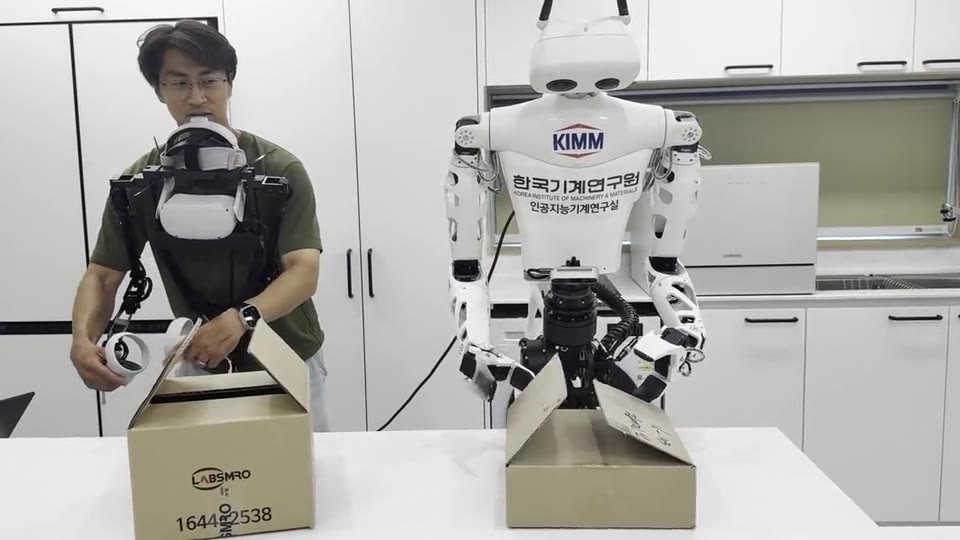
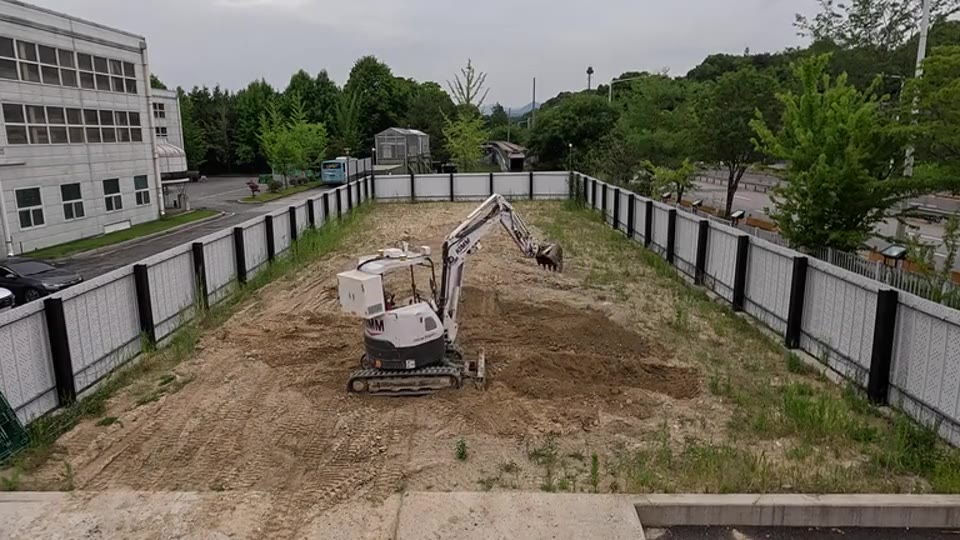
KAIROS and an autonomous excavator
Future Energy Solutions 2026
October 29, 2026 · Jeonbuk National University Convention Center
FES 2026 Special Address 1

Physical AI and the Future
of Industrial TransformationBuilding a Sustainable AI-Driven Ecosystem

Dr. Hanmin Lee Head, Industrial Machinery DX Laboratory
Korea Institute of Machinery & Materials (KIMM)
1

1. AI, Robots, and Industrial Machinery

Industries already wanted unmanned autonomy; ChatGPT accelerated it
OutlookAIHuang's 4 wavesRobotsModel → learning→ foundationMachineryAutomation → autonomy→ physical AI2010201220142016201820202022202420262028ChatGPT acceleratesPerception AISee, hear, recognizeGenerativeText, imageand codeAgenticPlans anduses toolsPhysical AISees the world,acts physicallyAlexNetAlphaGoChatGPTCES: physical AIModel-based controlClassical vision and controlPrecise repetition of set motionsLearning-based controlSimulation RL and imitation learningstarting with locomotionFoundation modelsVLA, RFM, plus world action modelsUnderstand language, predict, and act+ WAMPattern automationStructured repetitive workMachine control and guidanceSmart construction andautonomySensor fusion, path planningRemote and semi-autonomousField robot physical AILearning-based autonomous workExcavators and farm machines
2

2. From Programming to Learning

Learning from data and experience to handle more diverse tasks and environments
Programming-centric
Human designs motion→Execute
FANUC tablet teach pendant
→
Learning-centric
Demos, experience→Learn→Execute
Figure Helix 2.5 (2026.09)
3

3. Two Approaches to Action: VLA and WAM

VLA links understanding to action · WAM acts by predicting the future

VLAVision-Language-Action

Chef Robotics · Physical Intelligence Pi API
Burger assembly

WAMWorld Action Model

1X World Model · NEO
Pulling a tissue
4

4. How Robot Brains Are Structured

One model outputs actions directly, or understanding and control are split
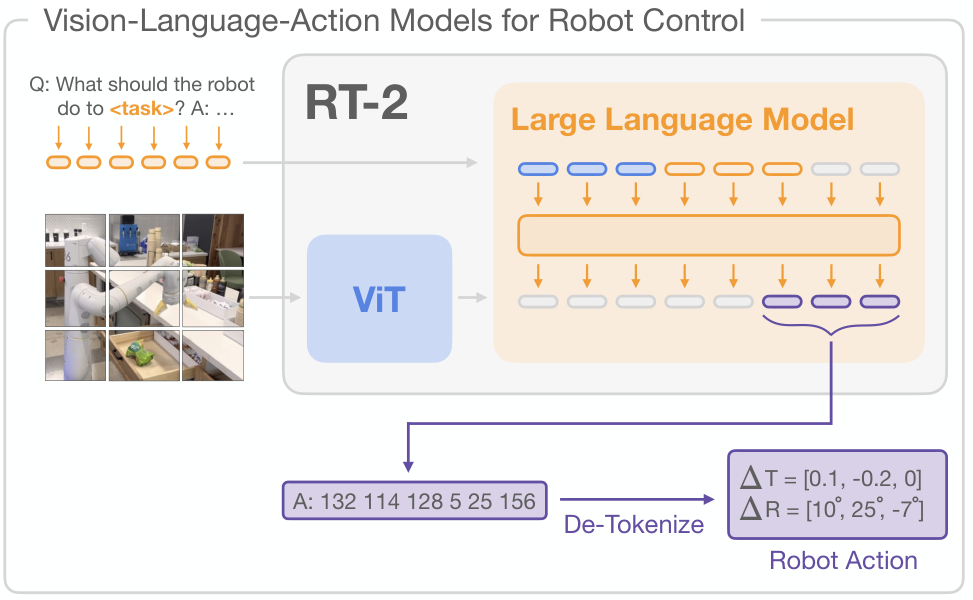
Direct actionGoogle DeepMind RT-2 (2023)
RT-2 Vision-Language-Action model diagram
↑Inputs
↑Action tokens → robot motion
One VLA model outputs action tokens directly
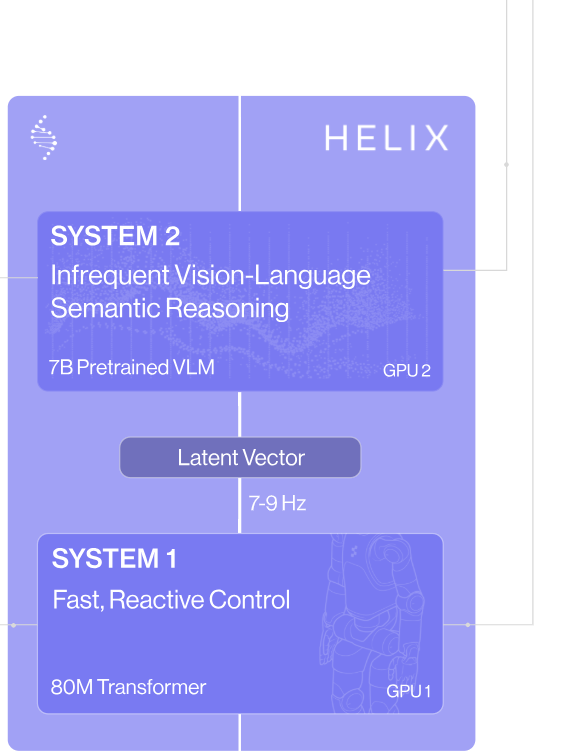
Split rolesFigure Helix (2025.02)
Figure Helix System 2 and System 1 diagram
Reason→
Control→
System 2 understands; System 1 moves
5

5. The Data Gap in Robot Learning

Compared with knowledge on the internet, robots lack action experience
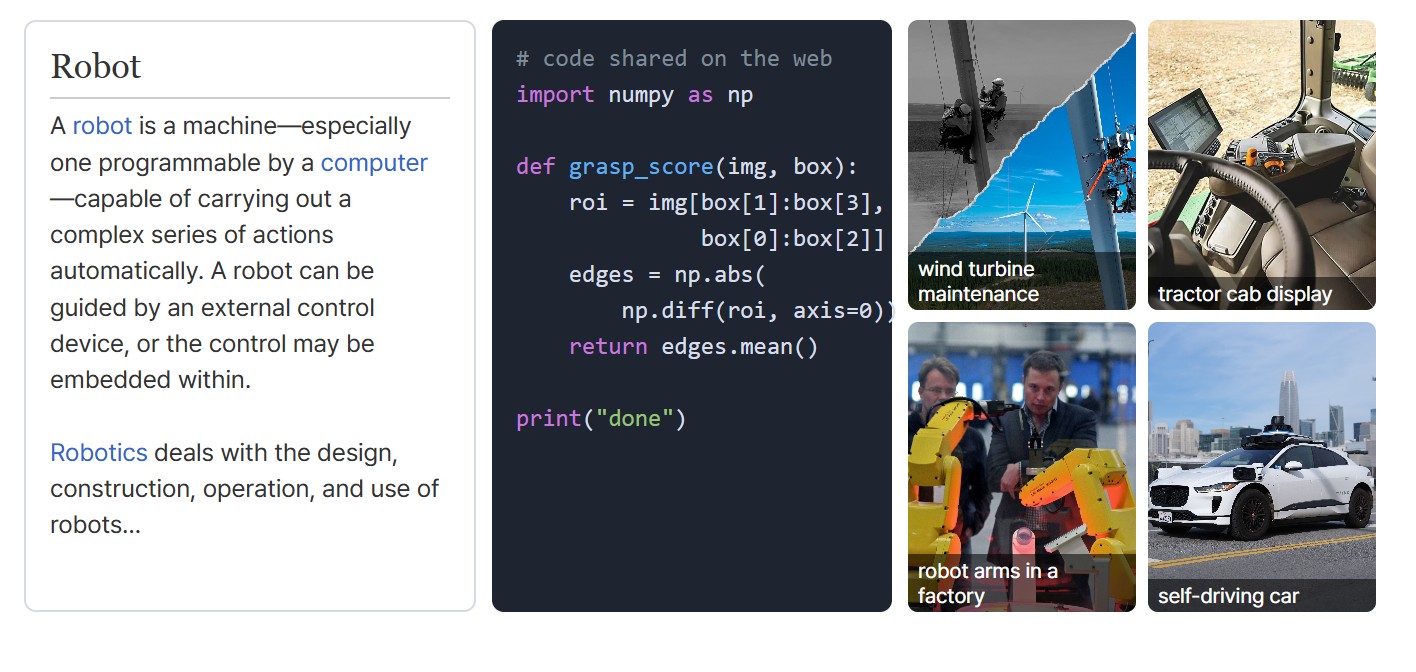
Text and images on the internet
Example web documents, code, and imagesWeb data example
vs
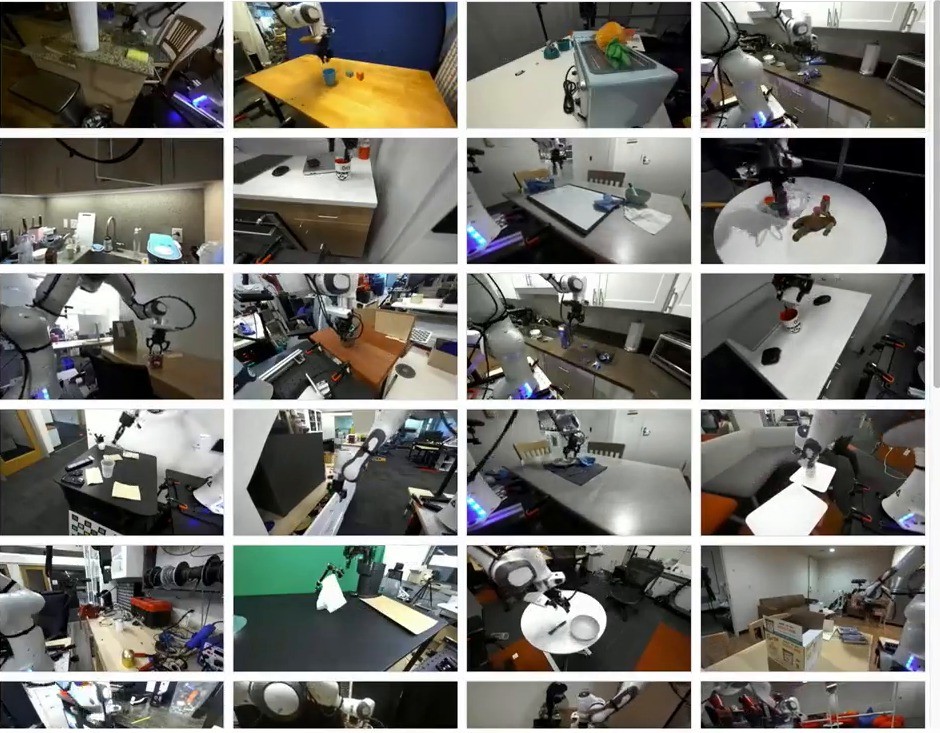
Robot teleoperation experience
DROIDRobot demonstration data example
Goldberg (2025) comparison at the time
~100,000 years
Time for a person to read and view the training text and images
~1 year
Cumulative recording time of the largest teleoperation dataset then
Robots need experience that links observation, action, and outcome
6

6. Acquiring and Scaling Training Data

Collect with robots, learn from people, and scale with synthetic data
1Teleoperation
Stanford, Mobile ALOHA (2024)
Records views and actions
+
2Human video
Human first-person video
▼ Used for training
Robot navigation
Figure, Project Go-Big (2025.09)
Navigation from human video
+
3Synthetic data
A few demos
▼ Augmented by new layouts
Many varied trajectories
NVIDIA, DexMimicGen (2024)
Demos augmented in simulation
Sim augmentationWorld models
Scale with diverse experience, then calibrate and validate on real tasks
7

7. Requirements for Field Deployment

Field criteria: reliable completion, sustained operation, productivity per cost
1Task reliability
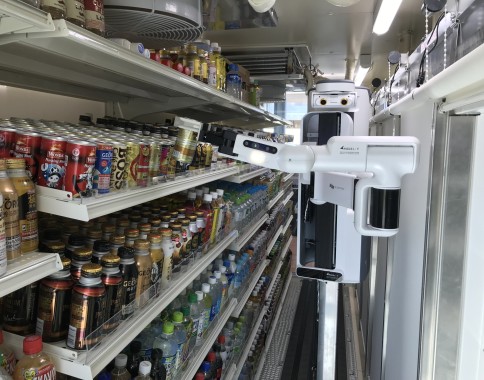
Telexistence TX SCARA
Telexistence, drink restocking in Japan
One operator monitors ~50 robots
Exceptions such as dropped items
are recovered by remote operators
→
2Sustained operation
Figure 02, BMW Plant Spartanburg
1,250+ h total, 90,000+ parts
11-month cumulative record, not uptime
Forearm, the top failure point, redesigned
→
3Economics
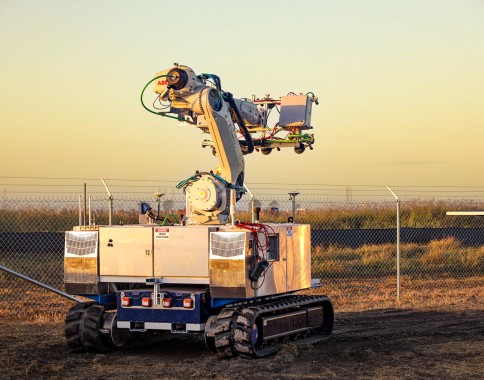
Rosendin solar installation robot
Rosendin, US solar field test
2 people, 350–400 panels / 8 h
3x the rate of a 3–4 person manual crew
A productivity gain, not proof of ROI
Beyond task success, the field needs recovery from failure and continuous operation
8

8. Humanoid Robots

Repetitive logistics tasks in commercial use; complex work still in demos and pilots
Agility Digit
TaskMoves totes from AMRs to conveyors
SiteGXO warehouse (Georgia)
StatusCommercial contract, 100,000+ totes moved
Figure 03
TaskParts sequencing, pulling carts
SiteBMW Spartanburg logistics hall
StatusOn-site demo of factory logistics work
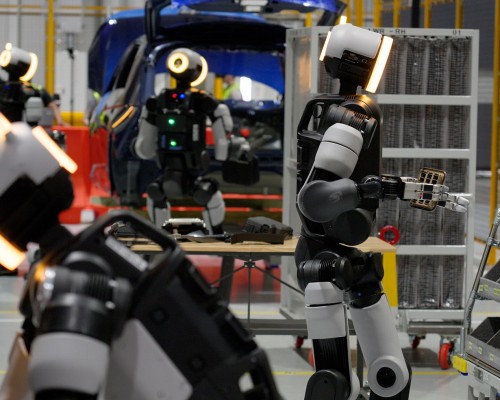
UBTECH Walker S
TaskCarrying and sorting parts boxes
SiteBYD, Zeekr, Foxconn and other plants
StatusPilots in car plants, scale undisclosed
9

9. Autonomous Driving

Driverless commercial service in set areas and routes, growing city by city, route by route
Waymo
TaskUrban passenger rides (robotaxi)
SiteDefined service areas in Phoenix, LA, etc.
StatusPaid driverless rides; remote staff only advise, the car drives
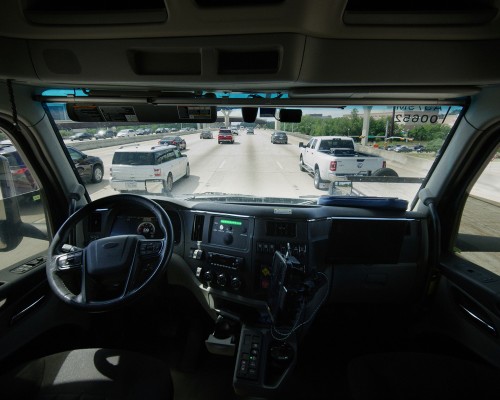
Aurora
Aurora
TaskHighway freight
SiteDesignated highway lanes in the US South
StatusCommercial runs with an empty cab, expanding lane by lane
Baidu Apollo Go
TaskUrban passenger rides (robotaxi)
SiteDefined service areas in China, Dubai, etc.
StatusFully driverless service in some cities, expanding city by city
10

10. Manufacturing and Logistics

Individual logistics tasks in commercial use; humanoids expanding into more processes
Amazon Vulcan
Amazon Vulcan
TaskStowing and picking items in storage pods
SiteAmazon fulfillment centers (US, Germany)
StatusIn operation; handles ~3/4 of items, hands off the rest
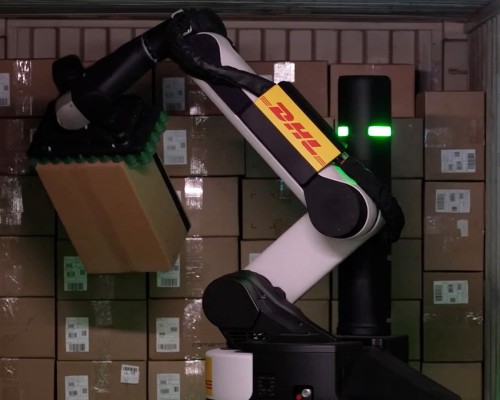
Boston Dynamics Stretch
TaskUnloading boxes from containers
SiteDHL warehouses in North America, UK, Europe
StatusCommercial since 2023, MOU for 1,000+ more (2025.05)
Hyundai Motor Group × Atlas
TaskAuto parts logistics and sequencing
SiteHyundai Metaplant America (Georgia)
StatusTraining on parts logistics; assembly planned by 2030
11

11. Defense

Supply, security, evacuation first — still remotely operated and supervised by people
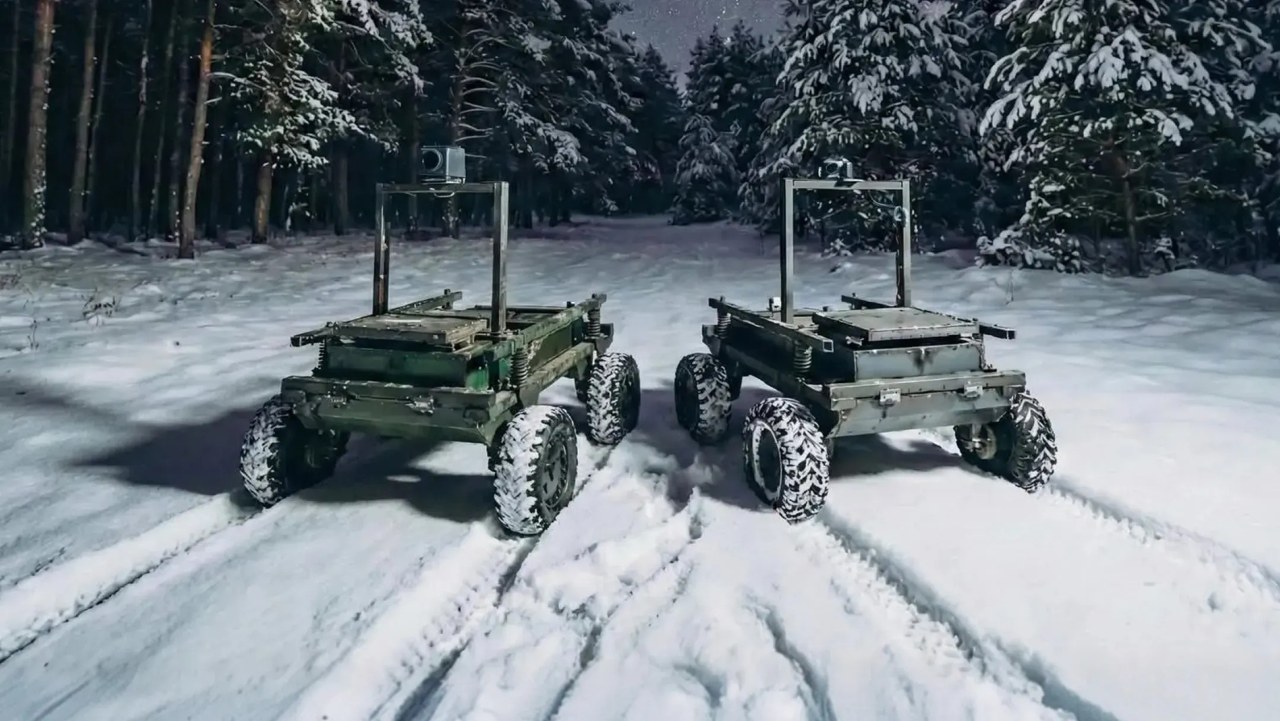
s12_ukraine_ugv_1280
Ukrainian ground robots
TaskFront-line ammo and food supply, casualty evacuation
SiteUkrainian front-line units (2026)
StatusCombat use, remote-controlled; ~66,000 missions Jan–Jun (MoD)
US Army S-MET
TaskCarrying squad gear and supplies
Site10th Mountain Division training (2025.01)
StatusProgram of record, remote-controlled by soldiers
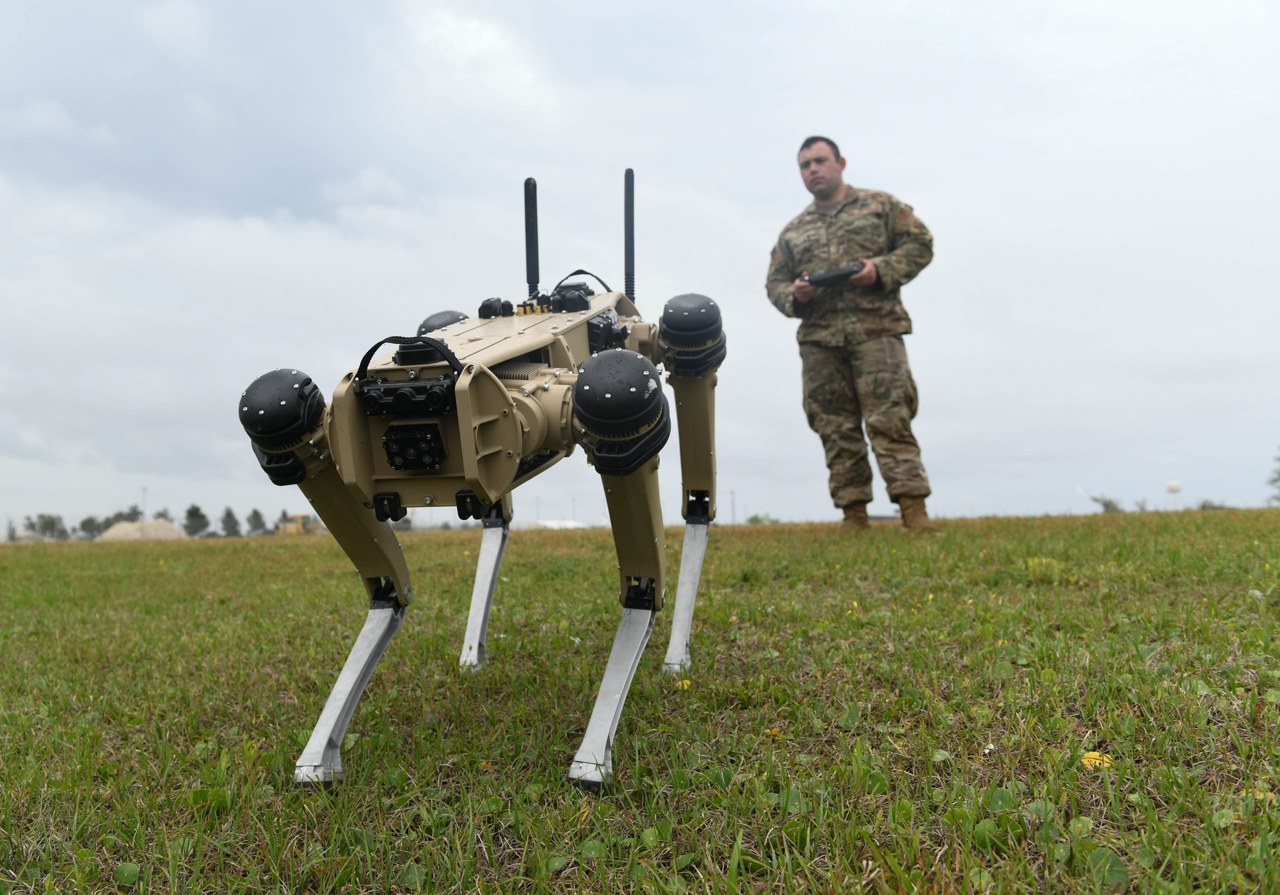
s12_tyndall_qugv_1280
Ghost Robotics Vision 60
TaskBase perimeter patrol and surveillance
SiteUSAF Tyndall AFB security forces (2021)
StatusSemi-autonomous patrol, pilot supervised by guards
12

12. Agriculture

Precision tasks in commercial use; driverless operation early, under remote supervision
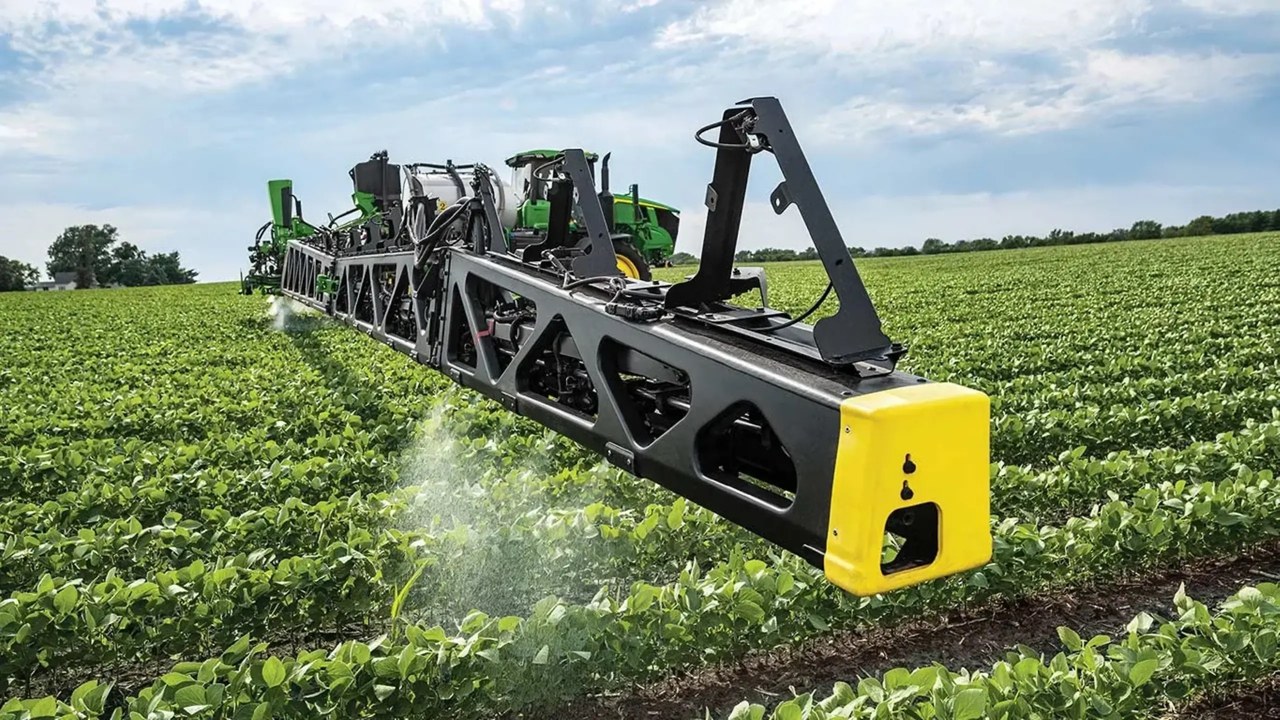
s13_deere_see_spray_1280
John Deere See & Spray
TaskCameras spot weeds and spray only them
SiteUS corn, soybean, cotton fields
StatusCommercial, with a driver; 5M+ acres in 2025 (company)
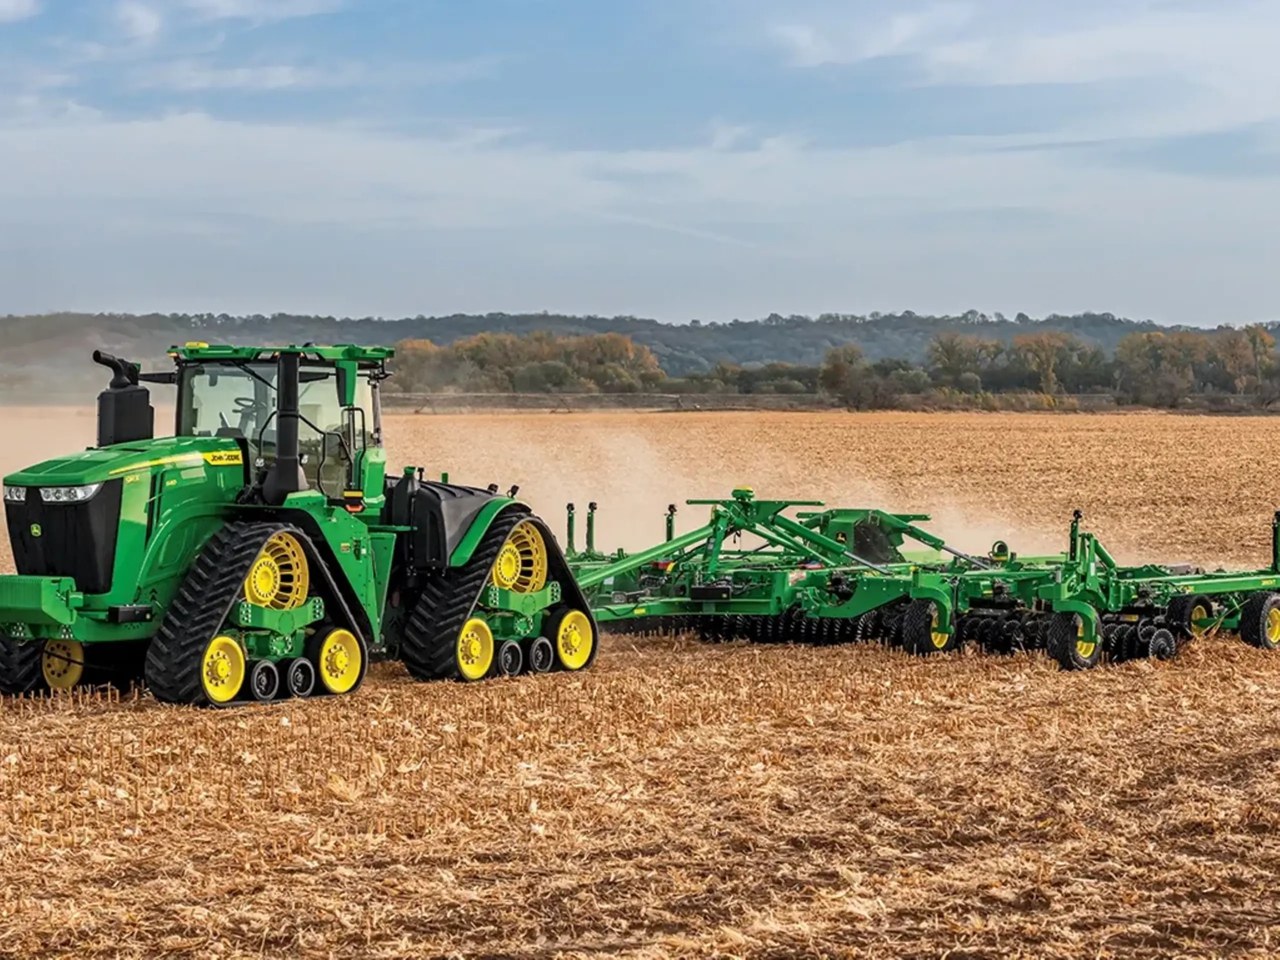
s13_deere_autonomous_9rx_1280
John Deere autonomous tractor
TaskDriverless tillage with an empty cab
SiteUS farms
StatusTillage only, supervised remotely by smartphone
Carbon Robotics LaserWeeder
TaskAI finds weeds, lasers remove them
SiteVegetable farms in the US, Europe, Australia
StatusCommercial, tractor-towed; driverless version early
13

13. Construction

Starting with pile driving and excavation — supervised unmanned operation begins
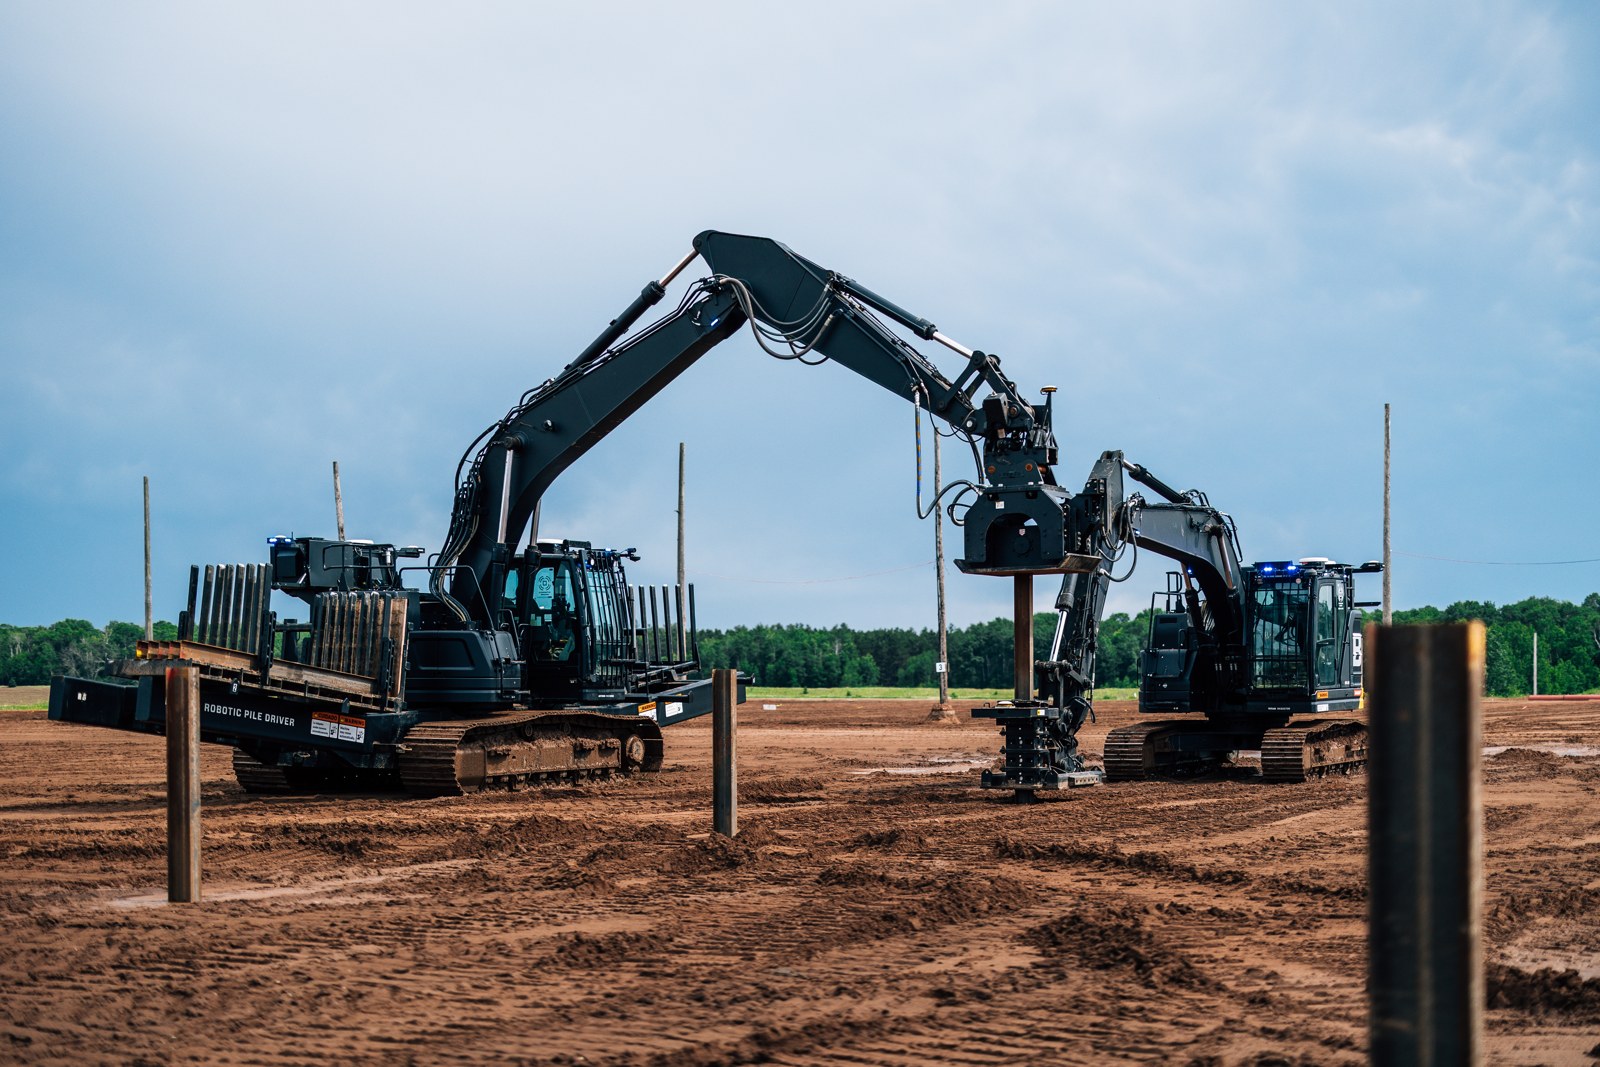
s14_built_rpd35_1600
Built Robotics RPD 35
TaskSolar pile layout and driving
SiteUS utility solar sites (Blattner, etc.)
StatusCommercial; unmanned zone, supervisor resupplies
Bedrock Robotics
TaskDigging and loading dump trucks
Site3 US sites (Zachry, Sundt, etc.)
StatusEmpty cab, approved conditions; stops for people
s14_gravis_truckload_1280
Gravis Robotics
TaskTrenching, earthmoving, truck loading
SiteManchester Airport, Holcim quarry
StatusAssist to remote; one person, many machines
Start with limited tasks, then widen the scope through expert know-how and field validation
14

14. The Evolution of KIMM's Robotics Research

Machine intelligence expanding into humanoid, field, and medical robots
Humanoids
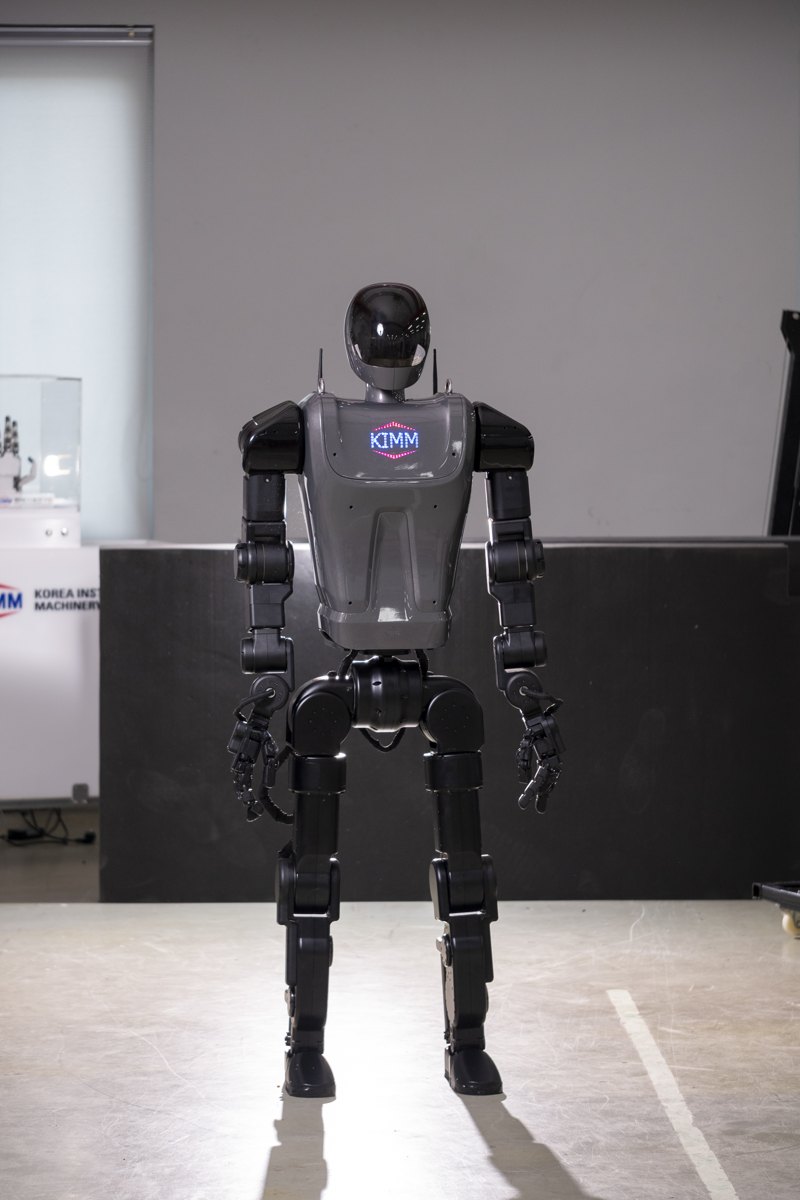
Humanoid KAIROS
Work in human environments
Field robots
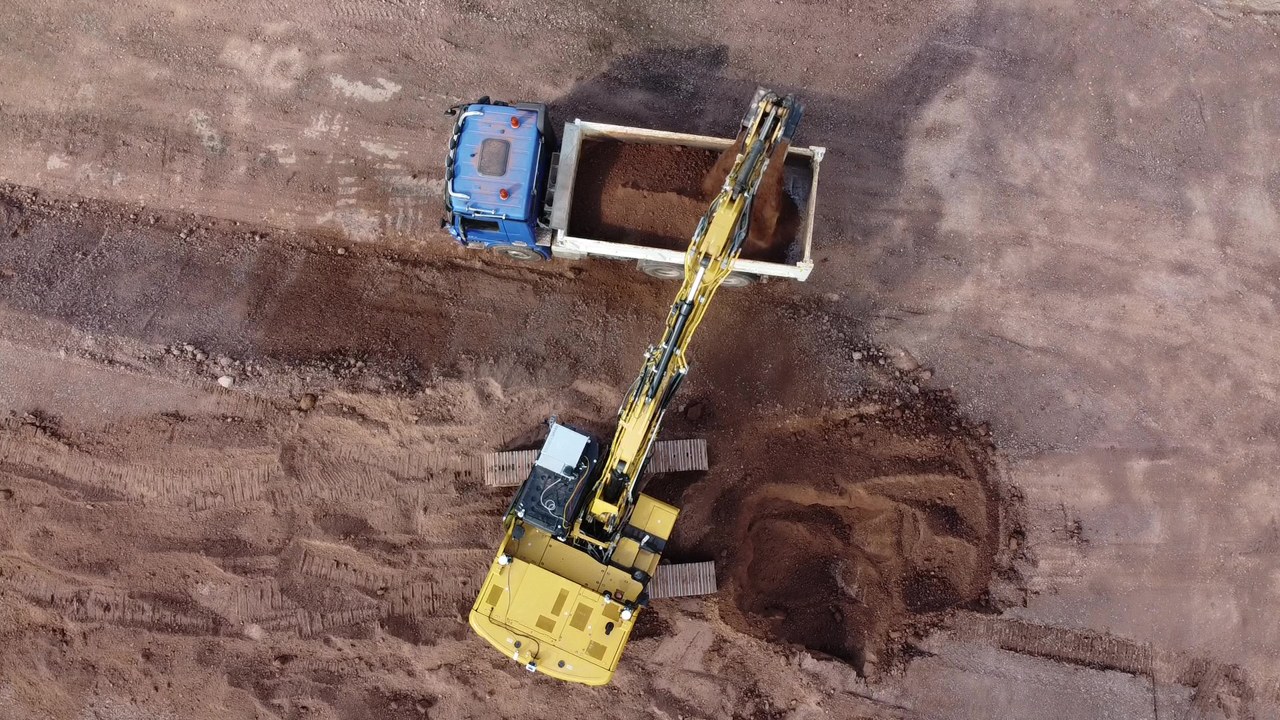
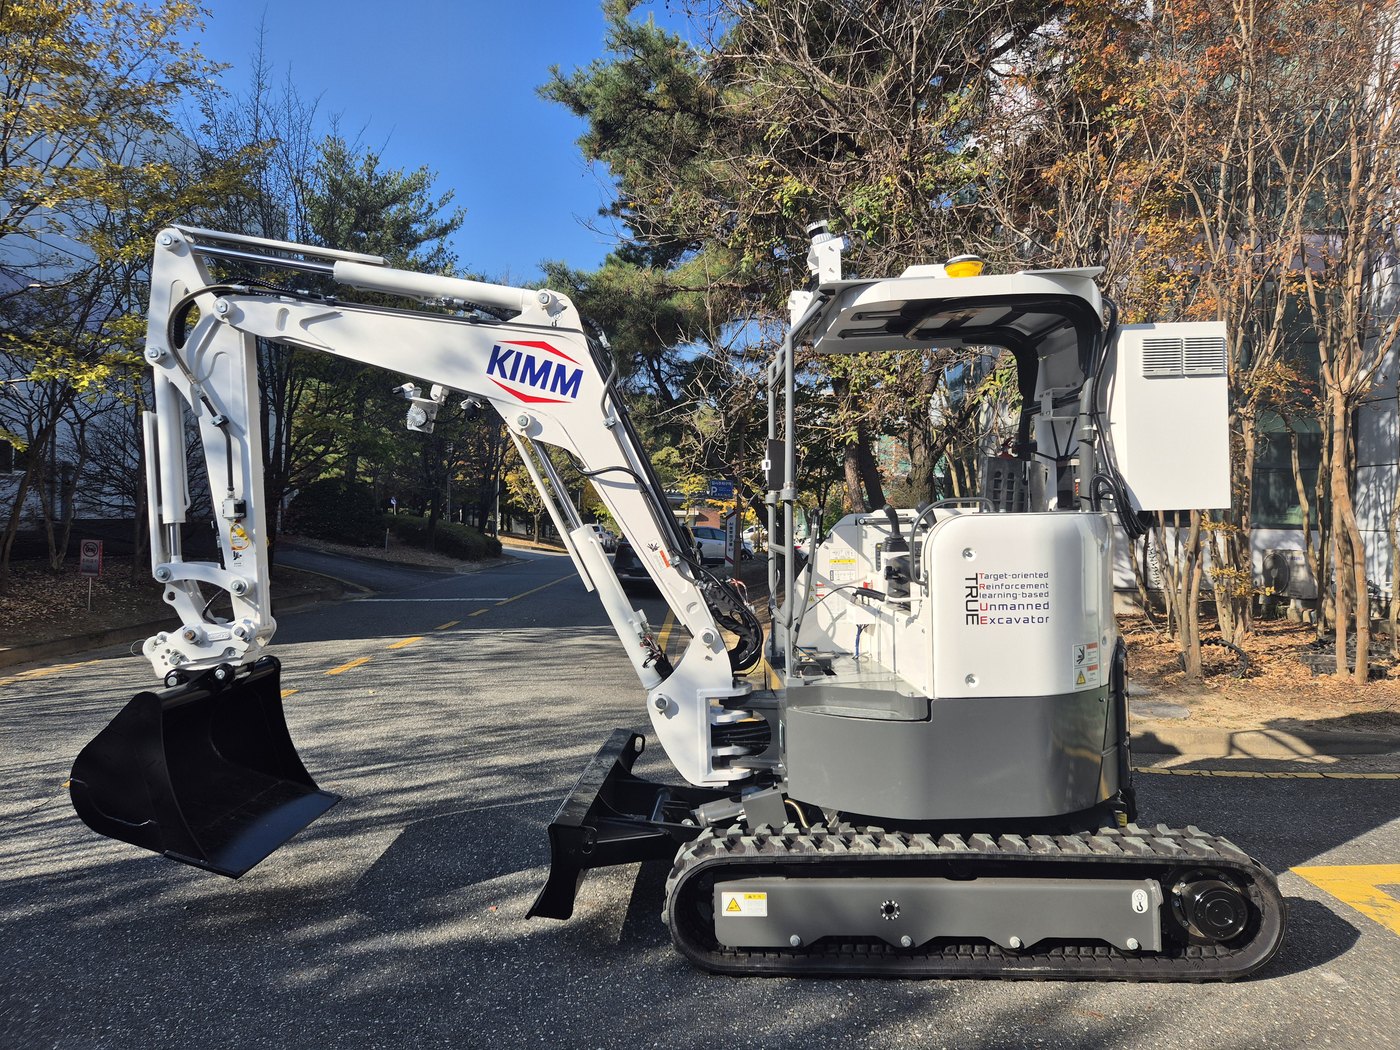
KIMM autonomous excavator
Work at industrial and disaster sites
Medical robots
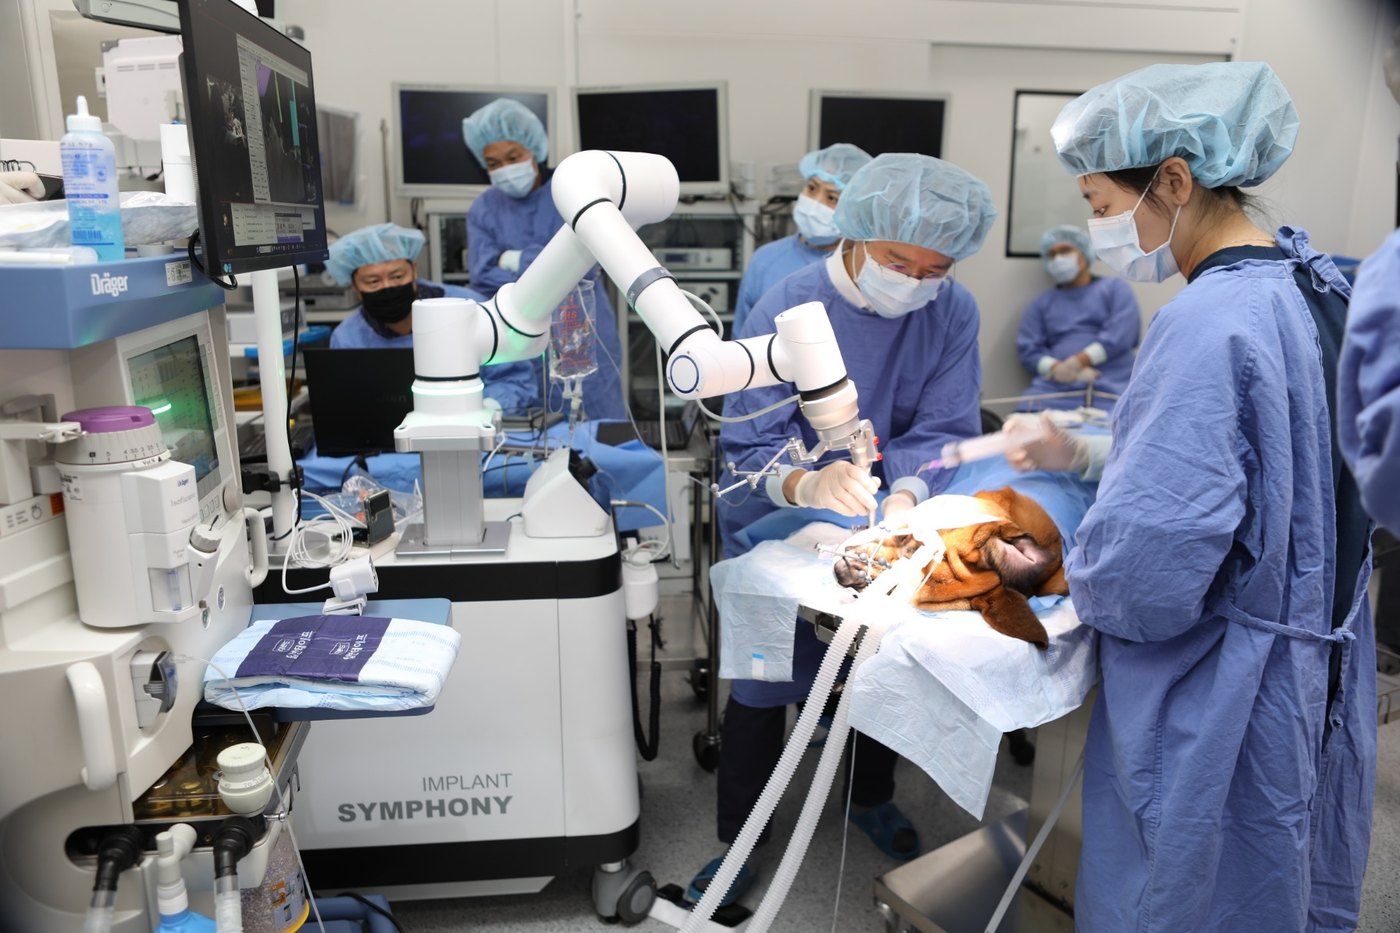
KIMM medical robot in an operating room
Precise medical tasks
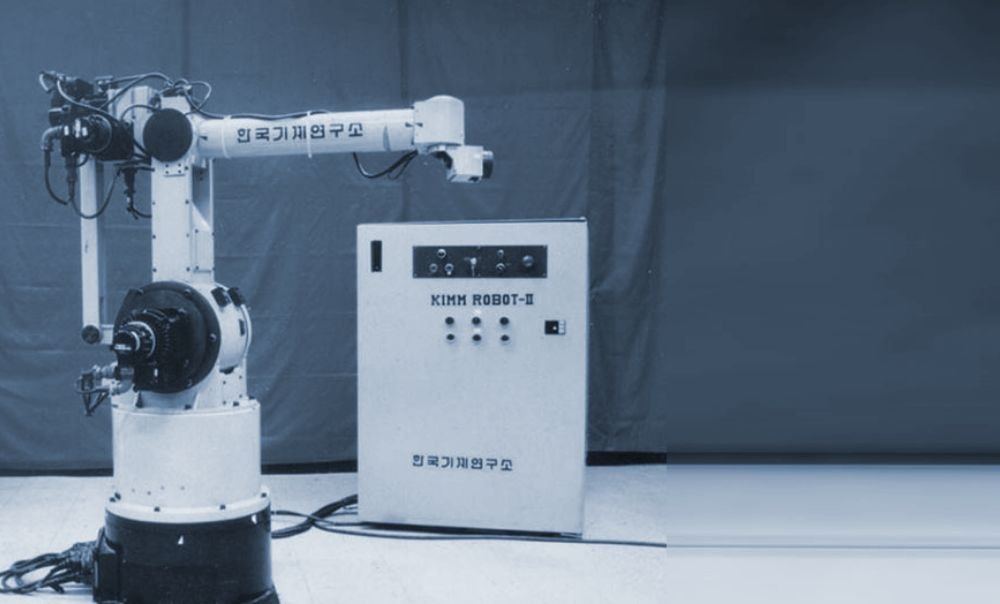
6-axis industrial robot
1986 Korea's first 6-axis industrial robot
▶
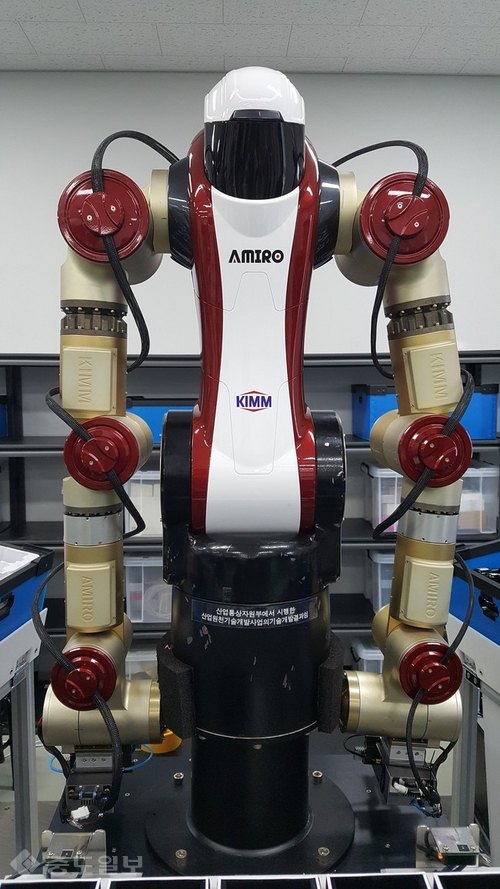
Dual-arm robot AMIRO
2010 Dual-arm robot AMIRO
▶
Now Humanoid KAIROS V0.7
15

15. Humanoid KAIROS

Developing robot platforms and core components for mobility and manipulation
2026 Global Mechanical Technology Forum Sep. 7, 2026
KAIROS V0.7 mask-dance demo
Roadmap2027.4V1▶2030.4V2 whole-body sensing▶2035Practical use
Actuator
2.1 kg,
up to 192 N·m
5 in-house actuator types, 20% higher performance
Robot hand
Holds tweezers
for tiny parts
Built on years of hand research
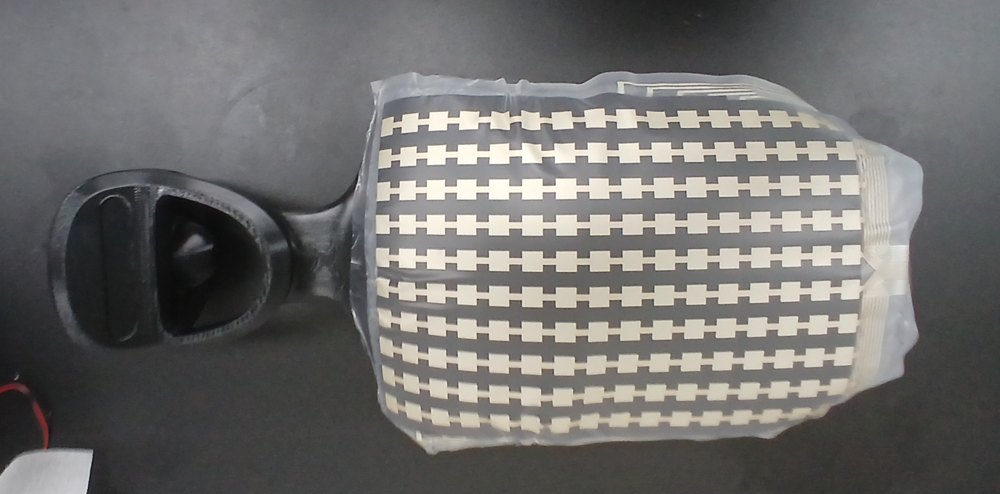
Large-area torso tactile sensor
Tactile skin Unique
Senses even
a gentle stroke
3-axis touch, self-healing skin
16

16. Robot Task Intelligence and Training Data

Learning from human demonstrations to scale to diverse tasks
1Collect demos
2Plan
3Execute tasks RoGeTA
RoGeTA teaching device
collects human demos
Data factory
Collecting demos from many humanoids at once
▶
Command understandingLanguage-vision model
Task planningSequencing and checks
Skill compositionPick, place, recover
▶
Table tidying
Recycling sorting and handover
17

17. Autonomous Field Robot Work

Automating construction and agricultural tasks that require skilled operators
ConstructionAutonomous trench excavation
KIMM 3.5-ton autonomous excavator
Terrain grid → digging point
Target depth 0.60 mMeasured avg. 0.63 m
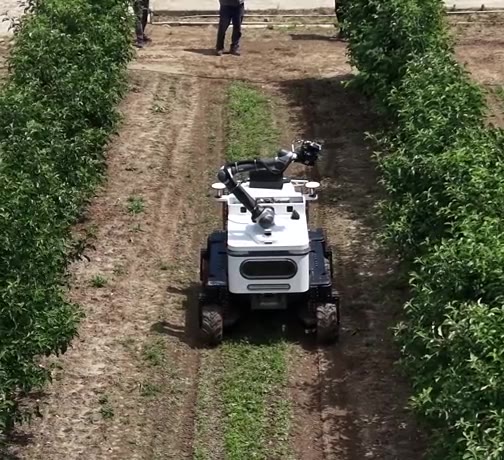
AgricultureOrchard pest scouting
Autonomous driving in an open orchard
Detecting pests among leaves
Scouting once done by eyeThe robot drivesand detects and logs on video
18

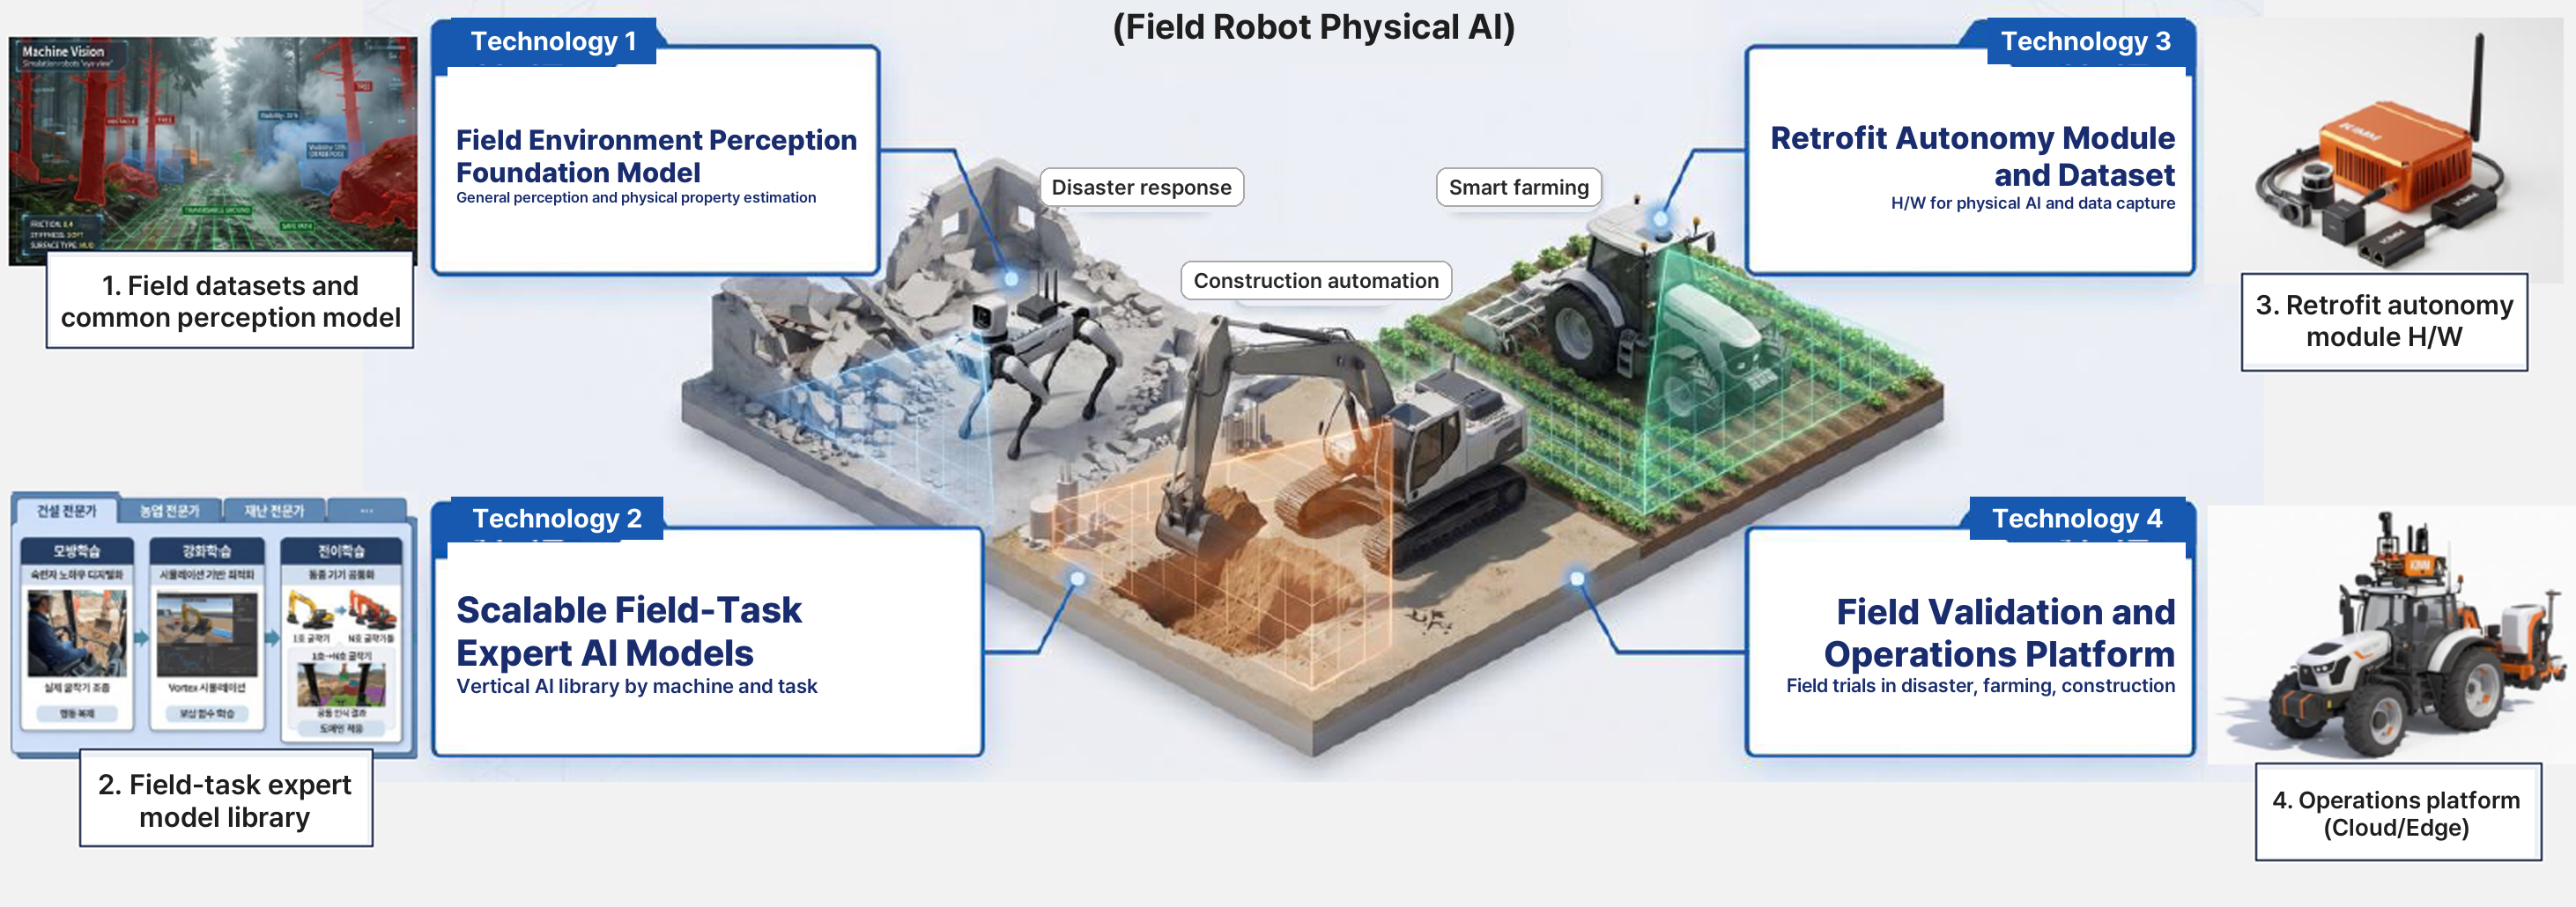
18. Field Robot Physical AI

One common perception model to automate construction, agriculture, and disaster equipment
Field robot physical AI technology components
AI field robots for labor shortages
and hazardous environments
Quadruped robot
Disaster quadruped
tractor
Agriculture tractor
Orchard scouting robot
Agriculture orchard scout
excavator
Construction excavator
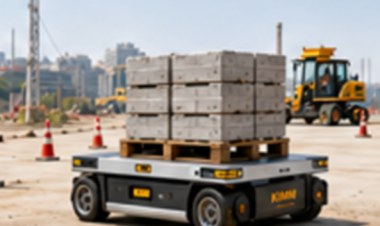
Material transport robot
Construction material carrier
5 machine typesLevel 4autonomy
19

19. Medical Robots

Expanding medical capability through precision manipulation and remote control
PrecisionMinimally invasive catheter robot
Catheter in a heart model
Steers the tip of a thin tube precisely, without tremor
RemoteRemote ultrasound, Ulleungdo–Daegu
Doctor · control
Robot · ultrasound
A remote robot follows the doctor's hand to acquire ultrasound images
20

20. Digital Twins

Linking real equipment and virtual twins in real time for learning and optimization
Real equipmentDigital twin
Autonomous tractor — field work monitored live in the twin
Digital twinReal machines
Autonomous machining cell — machine and robot motion synced with the twin
美 Digital Twin ConsortiumOfficial testbed
MANDATE-R2R Autonomous roll-to-roll battery manufacturing
Real equipment and twin linked in real time; multiple AI agents optimize the process · registered 2025.12
21

21. The Physical AI Industrial Ecosystem

From R&D to field use, connection builds industrial competitiveness
Teleoperation demo data
AI and dataModels and field data
+
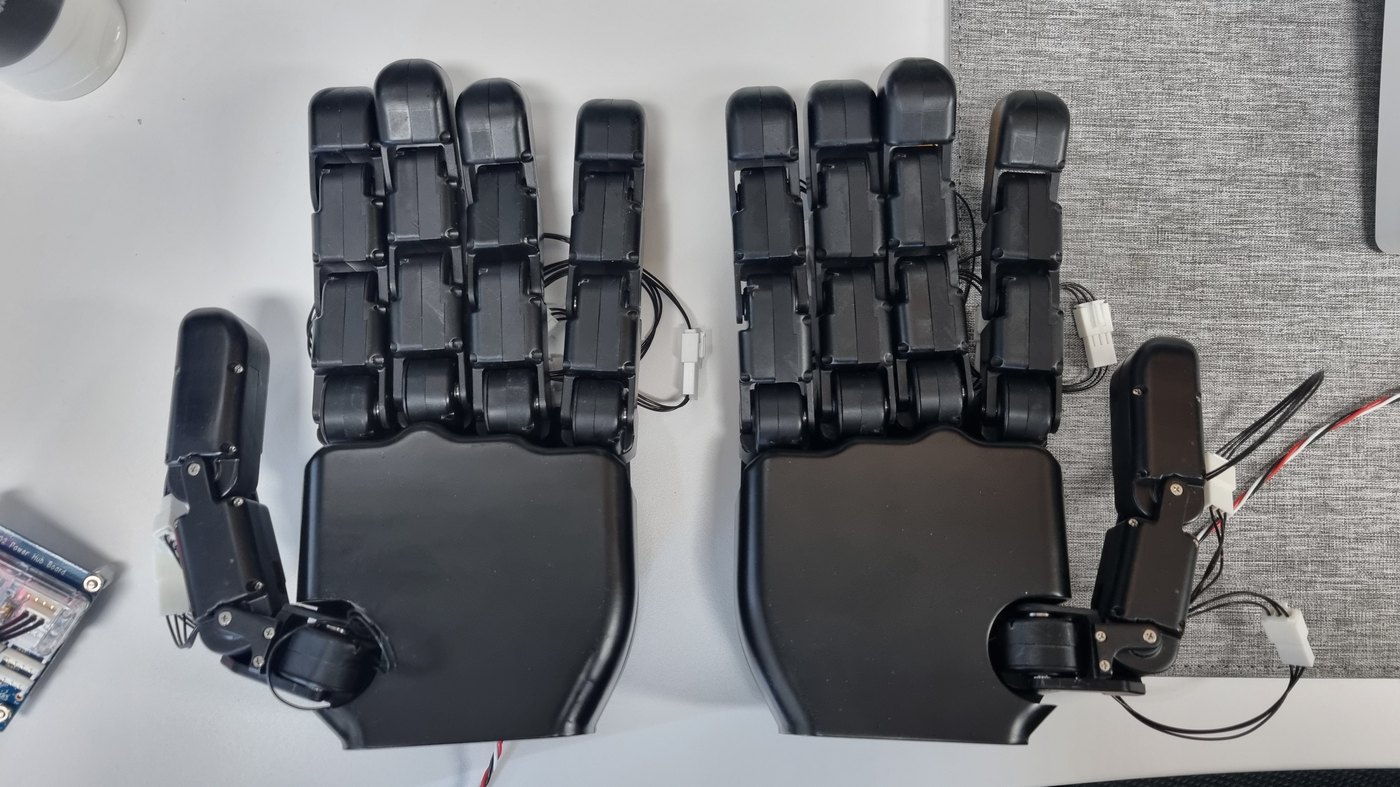
Robot hand
Core tech and partsActuators and robot hands
→
Integration
KAIROSKAIROS
Integrating into
field-ready robot systems
→
Testing and evaluation
Autonomous excavation test siteAutonomous excavation test site
Verifying performance and
safety in real conditions
→
Companies and industry
Orchard field robotOrchard field pilot
Deployed and used
at real work sites
Field experience feeds back into data and technology
KIMM develops core technology, integrates systems, and connects them to field validation
22

22. Physical AI and Energy

Energy powers robots, and robots work at energy sites
Energy
Power and charging — the basis for sustained work
Construction and inspection — hands for energy sites
Physical AI
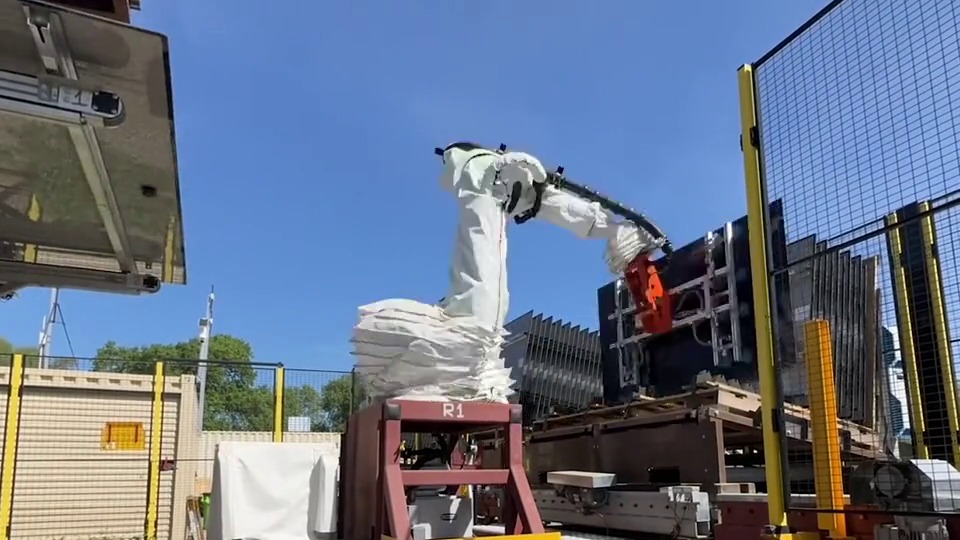
Terafab robot assembling solar modules© Terabase Energy
ConstructionTerabase Terafab
Robots on an on-site line automatically mount solar modules onto structures
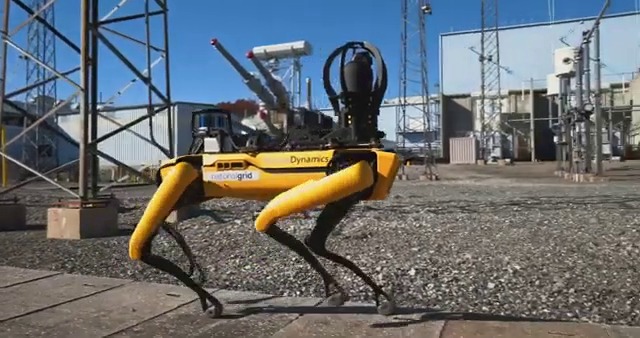
Spot patrolling a National Grid converter station© Boston Dynamics
OperationsNational Grid × Spot
Autonomous rounds and thermal checks at a converter station; hazardous areas run remotely from the control room
23

23. What Makes Physical AI Competitive

Tech×AI×Data×Energy×Supply chain×Security
The strength of each element, and the links between them, decide overall competitiveness.
24
Thank you. KIMM KIMM